Supervised Theses

Supervision: Prof. Klaus Werner Schmidt

2026 Theses

This is a list fo the theses completed in 2026 together with research infographics and short summaries where available.

2026

Additional M.Sc. Theses Completed in 2026

M.Sc. Thesis

Design and Evaluation of a Secure CAN XL Communication Framework with Session-Key Management and Authenticated Time Synchronization

Furkan Özen
August 2026
M.Sc. Thesis

A Real-Time, Tiled C++ Runtime Library for High-Definition Autonomous Vehicle Maps: Implementation and Evaluation

Salih Namık Özen
September 2026
M.Sc. Thesis

Development of a Deterministic, High-Speed, Multi-Level Multi-Drop Shared Communication Bus for Automotive Applications

Tan Çağatay Acar
September 2026
Co-advisor: Prof. Dr. Ece Guran Schmidt

Completed Ph.D. Theses

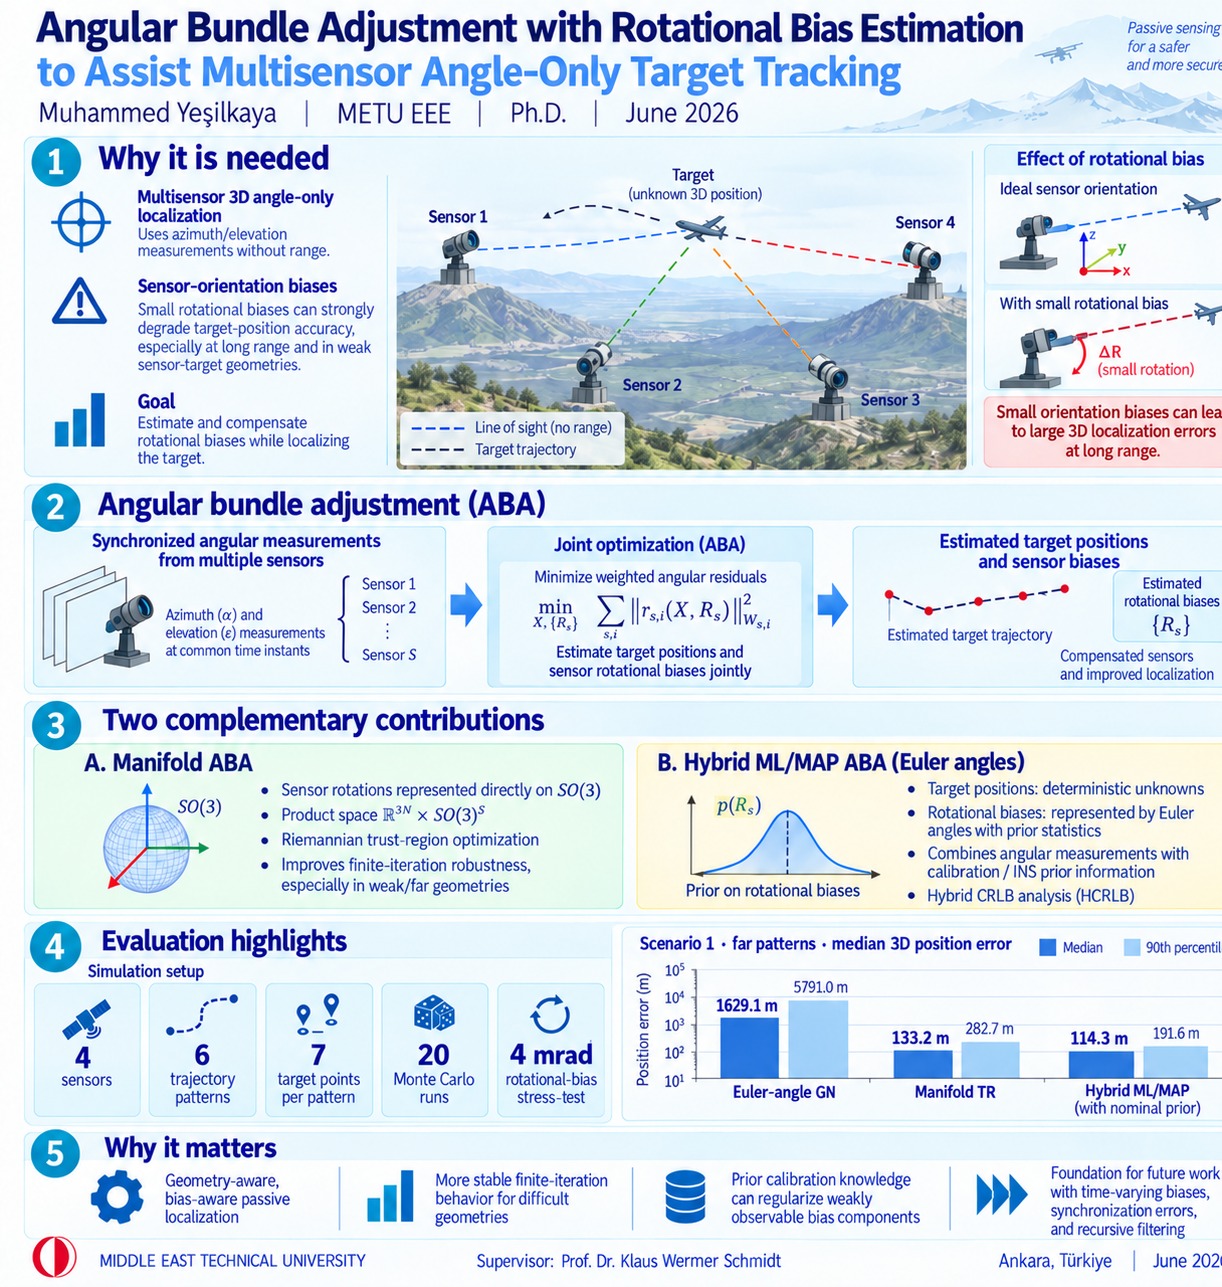
  1. Angular Bundle Adjustment with Rotational Bias Estimation to Assist Multisensor Angle-Only Target Tracking — Muhammed Yeşilkaya, 2026.
  2. RG-Trees: Nonlinear and deterministic extensions to reference governor trees — Ferhat Gölbol, 2025.
  3. Controller design for heterogeneous platoons in the presence of actuator saturation and time-varying communication delays — Hilal Bingöl, 2024.
  4. A general framework for the deterministic medium access on the controller area network — Murat Akpınar, 2022. Co-supervisor: Prof. Dr. Ece Guran Schmidt.
  5. Communication and coordination for urban intelligent transportation: Architecture and algorithms — Maksat Atagoziyev, 2022. Co-supervisor: Prof. Dr. Ece Guran Schmidt.
  6. Order-preserving models for discrete event systems: Theory and applications — Anas Nooruldeen, 2022.
  7. Trajectory planning and obstacle avoidance for omnidirectional robots — Mohammed Rabeea Hashim Al-Dahhan, 2020.
  8. Analysis of lane changes for vehicle strings on highways: String stability, driving safety and comfort — Hüseyin Buğra Sağlam, 2017.
  9. Optimal control problems for safe and efficient lane changes of self-driving vehicles — Ahmed Hussam Mohammed Ali, 2017.
  10. Model-based design of hierarchical control systems — Sebastian Perk, 2009.

Completed M.Sc. Theses (Supervised)

  1. A Real-Time, Tiled C++ Runtime Library for High-Definition Autonomous Vehicle Maps: Implementation and Evaluation — Salih Namık Özen, 2026.
  2. Development of a Deterministic, High-Speed, Multi-Level Multi-Drop Shared Communication Bus for Automotive Applications — Tan Çağatay Acar, 2026. Co-advisor: Prof. Dr. Ece Guran Schmidt.
  3. Design and Evaluation of a Secure CAN XL Communication Framework with Session-Key Management and Authenticated Time Synchronization — Furkan Özen, 2026.
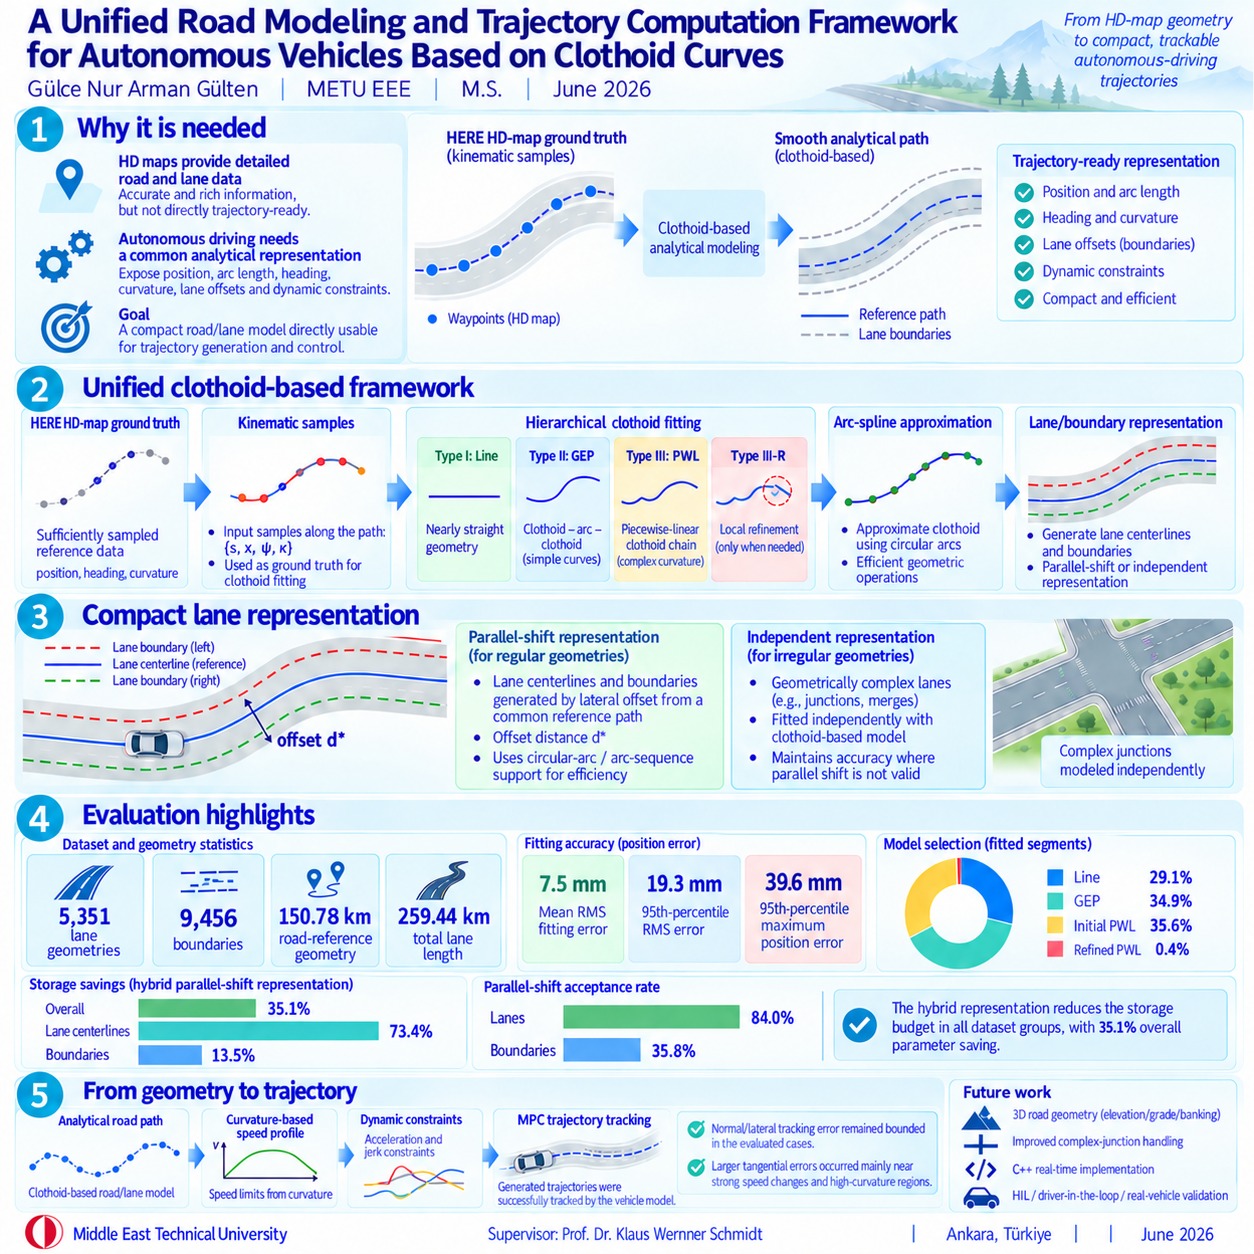
  4. A Unified Road Modeling and Trajectory Computation Framework for Autonomous Vehicles Based on Clothoid Curves — Gülce Nur Arman Gülten, 2026.
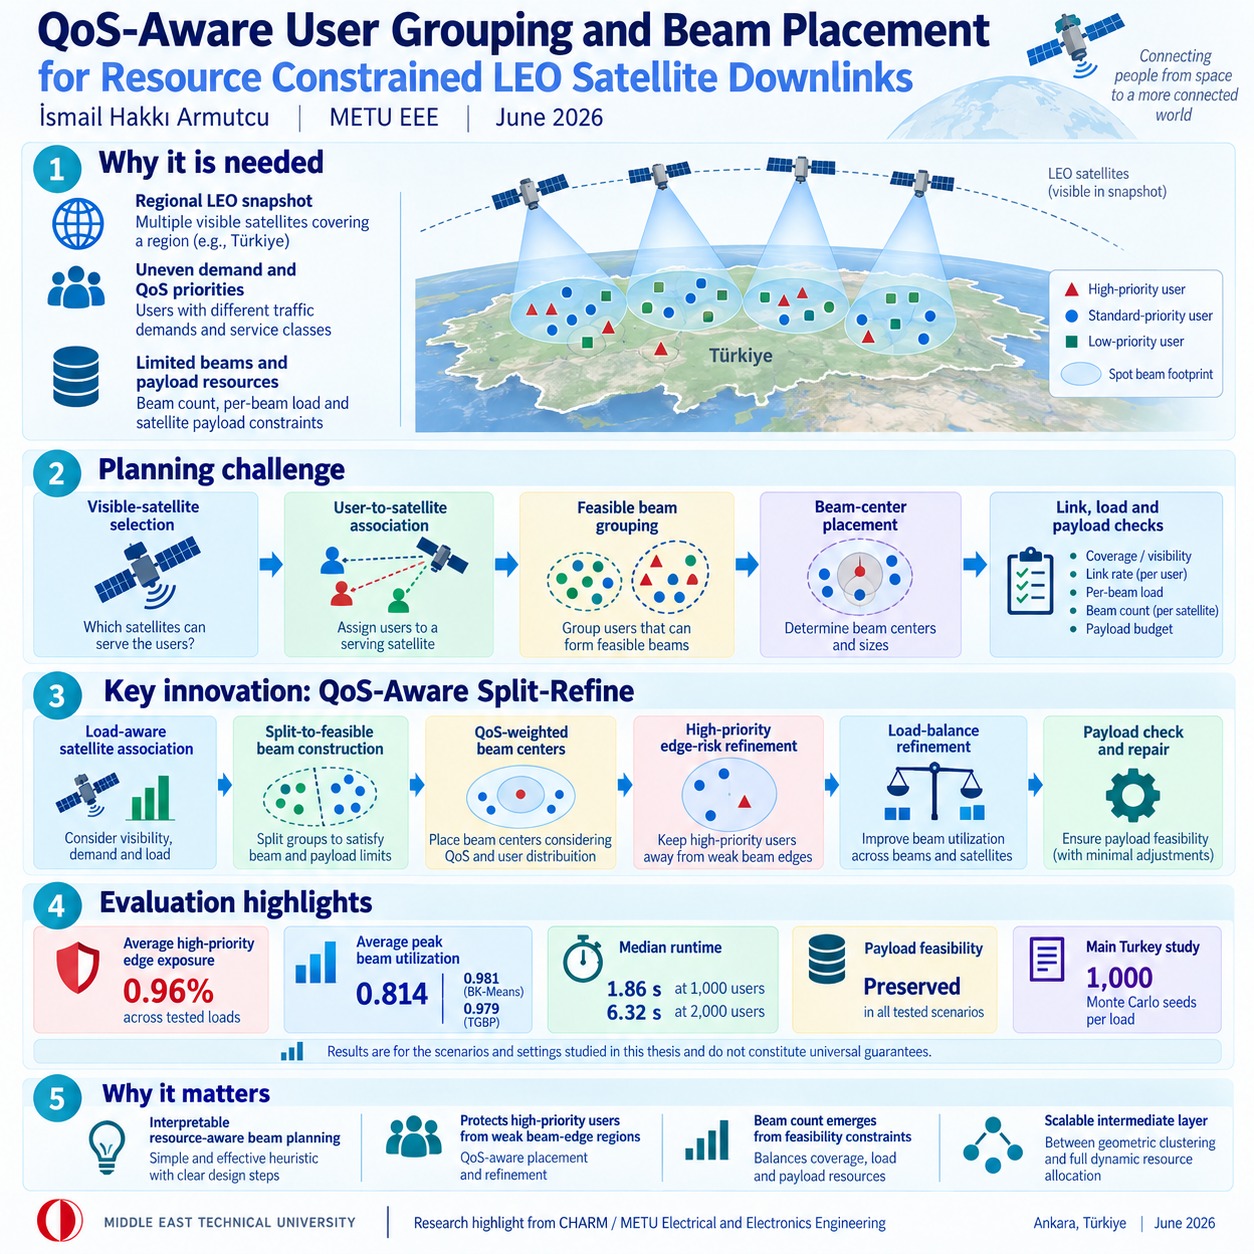
  5. QoS-Aware User Grouping and Beam Placement for Resource-Constrained LEO Satellite Downlinks — İsmail Hakkı Armutcu, 2026.
  6. Sensor processing and controller design for trajectory tracking of autonomous vehicles — Muzaffer Temelli, 2025.
  7. Predicting pedestrian crossing behavior with attention-based encodings of vehicle and pedestrian states — Mehmet Ali Kumral, 2025.
  8. An efficient road representation for autonomous vehicles using arc-splines with application to trajectory planning — Atakan Salih Bolat, 2024.
  9. Maneuver optimization for autonomous vehicles using trajectory templates — O.F. Arslan, 2024.
  10. Lane change prediction for autonomous vehicles using trajectory templates — İ.H. Yıldız, 2024.
  11. Estimation of vehicle signals for autonomous driving applications — Halil Temurtaş, 2022.
  12. Cooperative adaptive cruise control with predicted vehicle information: Development and evaluation — Furkan Kılıç, 2022.
  13. Linear parameter varying control for autonomous systems: Methods and application examples — Fatih Çalış, 2022.
  14. Hierarchical and modular control of reconfigurable manufacturing systems — Övül Arslan, 2022.
  15. Transfer functions with positive impulse response: Feedback controller design and application to cooperative adaptive cruise control — İbrahim Tayyip İşler, 2021.
  16. Sensor fusion of a camera and 2D LIDAR for lane detection and tracking — Yasin Yeniaydın, 2019.
  17. String stability analysis of cooperative adaptive cruise control (CACC) with actuator saturation — Hilal Bingöl, 2017.
  18. Trajectory generation for open/close gap maneuvers in vehicle strings — Erkam Çankaya, 2017.
  19. Design and evaluation of cooperative adaptive cruise control (CACC) for the improvement of highway traffic flow — Ahmed M. H. Al-Jhayyish, 2016.
  20. Fault recovery for discrete event systems — Ayşe Nur Acar, 2015.
  21. Platooning of vehicles in intelligent transportation systems — Inas Deaibil, 2015.
  22. Applications of fault-tolerant supervisory control for discrete event systems — Sarmad Nozaad Mahmood, 2014.
  23. Design of a photovoltaic power converter for driving and controlling AC motors — Hamed Soodi, 2014.
  24. Applications of reconfigurable manufacturing systems: A laboratory case study — Harith M. Khalid, 2014.
  25. Design and implementation of a 1kW single phase grid tied inverter — Oğuz Şimşek, 2013.
  26. Driver design for asynchronous motors: Digital signal processing, control and data acquisition — Habib Özer Öz, 2012.
  27. Modeling, control and simulation of a drinking water treatment plant — Faisel Saber, 2012.
  28. Development of a water tank laboratory experiment — Abas Anwar, 2012.
  29. Supervisory control for reconfigurable manufacturing systems: Structural changes and re-usability of controllers — Anas Nooruldeen, 2012.
  30. Development of a DC-motor control laboratory experiment — Ardm Haseeb, 2012.
  31. Failure diagnosis for hierarchical and decentralized discrete event systems — Thomas Barthel, 2009.
  32. Aggregation of networked discrete event controllers: Theoretical development and simulation study — Ingo Petzoldt, 2008.
  33. Communication models for networked discrete event controllers — Jorgos Zaddach, 2007.
  34. Hierarchical control of discrete event systems: Computation of abstractions and maximal permissiveness — Christian Breindl, 2007.
  35. Finite state automata as a programming language for the IEC 61131-3 norm — Bernd Schlein, 2006.
  36. Methods of supervisory control: A software implementation — B. Opitz, 2006.
  37. Hierarchical design of discrete event controllers: An automated manufacturing system case study — Sebastian Perk, 2005.
  38. Design, implementation and validation of supervisory control for an automated manufacturing system — Stephan Figgen, 2005.
  39. Application of nonlinear control methods for the vibration isolation of commercial vehicle seats — Thomas Timm, 2003.
  40. Application and extension of decentralized supervisory control for discrete event systems — Gökben Ersoy, 2003.
  41. Development of a hardware-in-the-loop simulation environment for the study of semi-active dampers in commercial vehicle seats — Martin Seltsam, 2002.

Completed M.Sc. Theses (Co-Supervised)

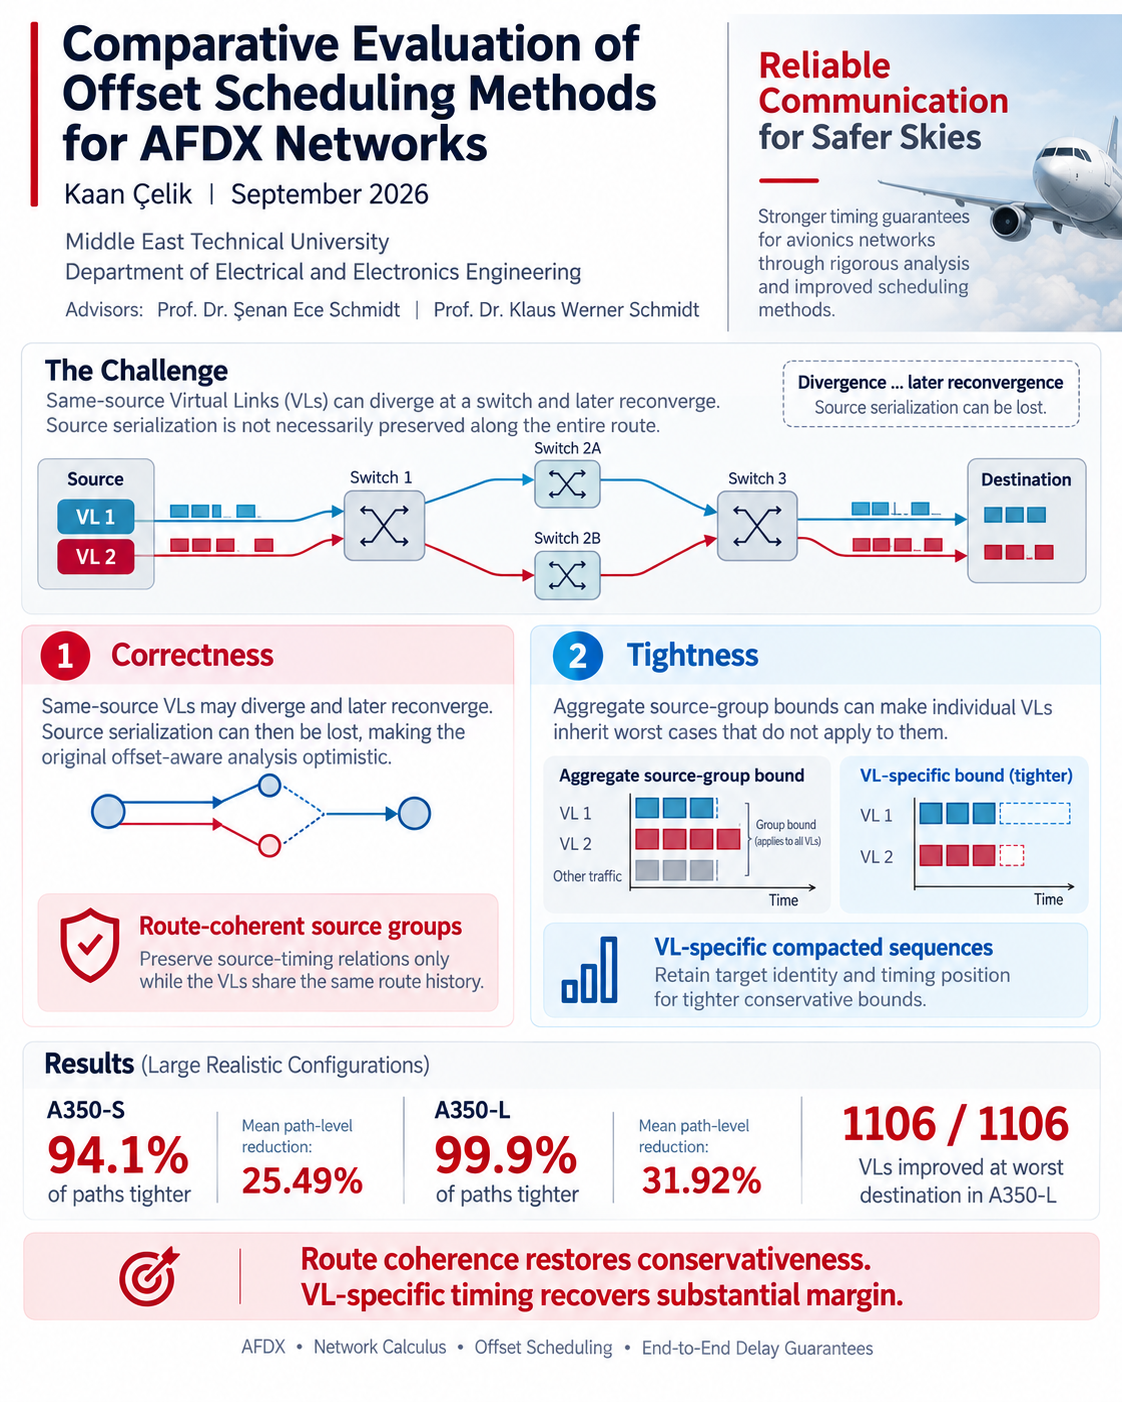
  1. Comparative Evaluation of Offset Scheduling Methods for AFDX Networks — Kaan Çelik, 2026. Joint advisors: Prof. Dr. Şenan Ece Schmidt and Prof. Dr. Klaus Werner Schmidt.
  2. Offset scheduling for AFDX: definition, response time computation, and evaluation — Muhammed Fatih Elgin, 2025.
  3. Dynamic, adaptive, and optimal resource allocation and migration in cloud data centers — Onat Deniz Doğan, 2025.
  4. Optimizing air conditioner system efficiency through reinforcement learning — Mehmet Burak Hekimoğlu, 2025.
  5. Optimal resource allocation and migration decision for virtual machine requests in cloud data centers — Nazım Kerem Mert, 2023.
  6. An analytical method for the analysis and design of AFDX networks — Zeynep Ayhan, 2023.
  7. Clock synchronization and weak TDMA for CAN FD: Implementation and evaluation — İsmet Onur Demirel, 2022.
  8. Clock synchronization algorithms on a software-defined CAN controller: Implementation and evaluation — Serkan Yalçın, 2020.
  9. Telegram scheduling for the periodic phase of the multifunction vehicle bus — Mustafa Çağlar Güldiken, 2020.
  10. Optimal dynamic resource allocation for heterogeneous cloud data centers — Nazım Umut Ekici, 2019.
  11. C3: Configurable CAN FD controller: Design, implementation and evaluation — Mehmet Ertuğ Afşin, 2018.
  12. Message scheduling for the static and dynamic segment of FlexRay: Algorithms and applications — Özgür Kızılay, 2016.
  13. Controller Area Network (CAN) response time analysis and scheduling for advanced topics: Offsets, FIFO queues and gateways — Burak Alkan, 2015.
  14. A frame packing method to improve the schedulability on CAN and CAN-FD — Gökhan Urul, 2015.
  15. Combined centralized and decentralized fault diagnosis for discrete event systems — Ruhi Karav, 2014.
  16. Diagnosers for discrete event systems: Improved realization and examples — Bora Eser Kart, 2014.
  17. Implementation and evaluation of the Dynamic Distributed Real Time Industrial Protocol (D2RIP) — Adem Kaya, 2013.
  18. Implementation and evaluation of the dependability plane for the Dynamic Distributed Dependable Real Time Industrial Protocol (D3RIP) — Ömer B. Sezer, 2013.
  19. An FPGA implementation of two-step trajectory planning for automatic parking — Halil Erturgul, 2013.
  20. Software tool development for the automated configuration of FlexRay networks for in-vehicle communication — Can Öztürk, 2013.
  21. Reducing worst-case message response times on CAN networks — Vakkas Çelik, 2012.